Nanjing DCS Modbus TCP Master
Purpose
This plugin reads and writes coils and registers through the Nanjing DCS Modbus TCP session. The session performs a connection probe after reconnecting and handles the DCS leading status frame. It is named NanjingDcsMaster in the device selector.
See Collection Configuration for common channel, device, variable, data-format, and batch settings. This page covers only the fixed framing, DCS station, addresses, and debug.
Open the plugin
Open Development Configuration → Collection Configuration, create a TCP client channel, then create a device using NanjingDcsMaster.
Supported scope
| Item | Description |
|---|---|
| Channel | TCP client only. |
| Framing | Fixed to Modbus TCP. |
| Data types | Boolean, Byte, common signed/unsigned integers, Float, Double, and String. |
Plugin properties
| Setting | Default | Description |
|---|---|---|
| Modbus framing | ModbusTcp | Keep this value; RTU and ASCII are not supported. |
| DCS station | 1 | Used by the reconnect probe and when the variable address omits a station. |
Multi-byte values use CDAB by default. Keep the common batch limits unless the DCS requires smaller frames.
Address rules
| Address | Area | Common read function |
|---|---|---|
00001 | Coils | FC1 |
10001 | Discrete inputs | FC2 |
30001 | Input registers | FC4 |
40001 | Holding registers | FC3 |
40001;s=2;reads the first holding register at station2.40001;w=16;uses FC16 for writes.- Addresses are one-based. Registers occupied by multi-register values must not overlap adjacent variables.
After each TCP reconnect, the plugin reads holding register zero at the configured station and waits for the DCS six-byte status frame. Use the standard Modbus collection plugin for an ordinary Modbus TCP device that does not provide this frame.
Special methods
This plugin has no additional special methods. Variables use standard Modbus addresses directly.
Functions
| Function | Purpose |
|---|---|
| Read and write | Read a confirmed point and write only to an approved test point. |
| Messages | View sent and received frames, protocol fields, and error details. |
Device debug
Open Development Configuration → Collection Configuration, select the Nanjing DCS device, and click More Functions, then open Debug. This plugin uses the Read/Write and Messages tabs.
| Feature | Purpose |
|---|---|
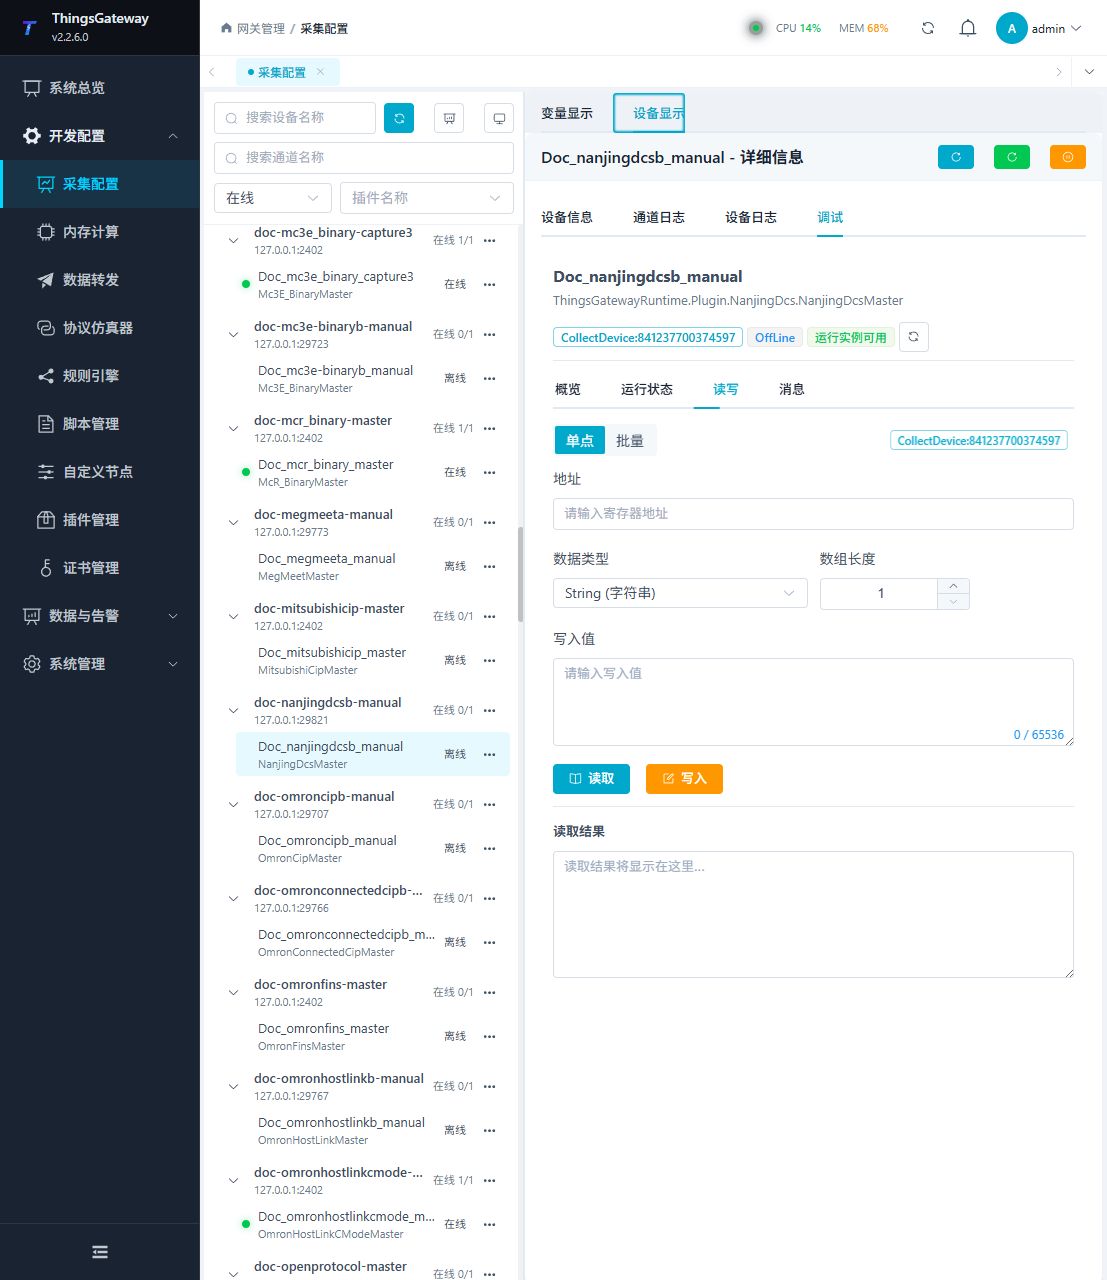
| Read/Write | Reads one DCS Modbus address or performs an approved write. |
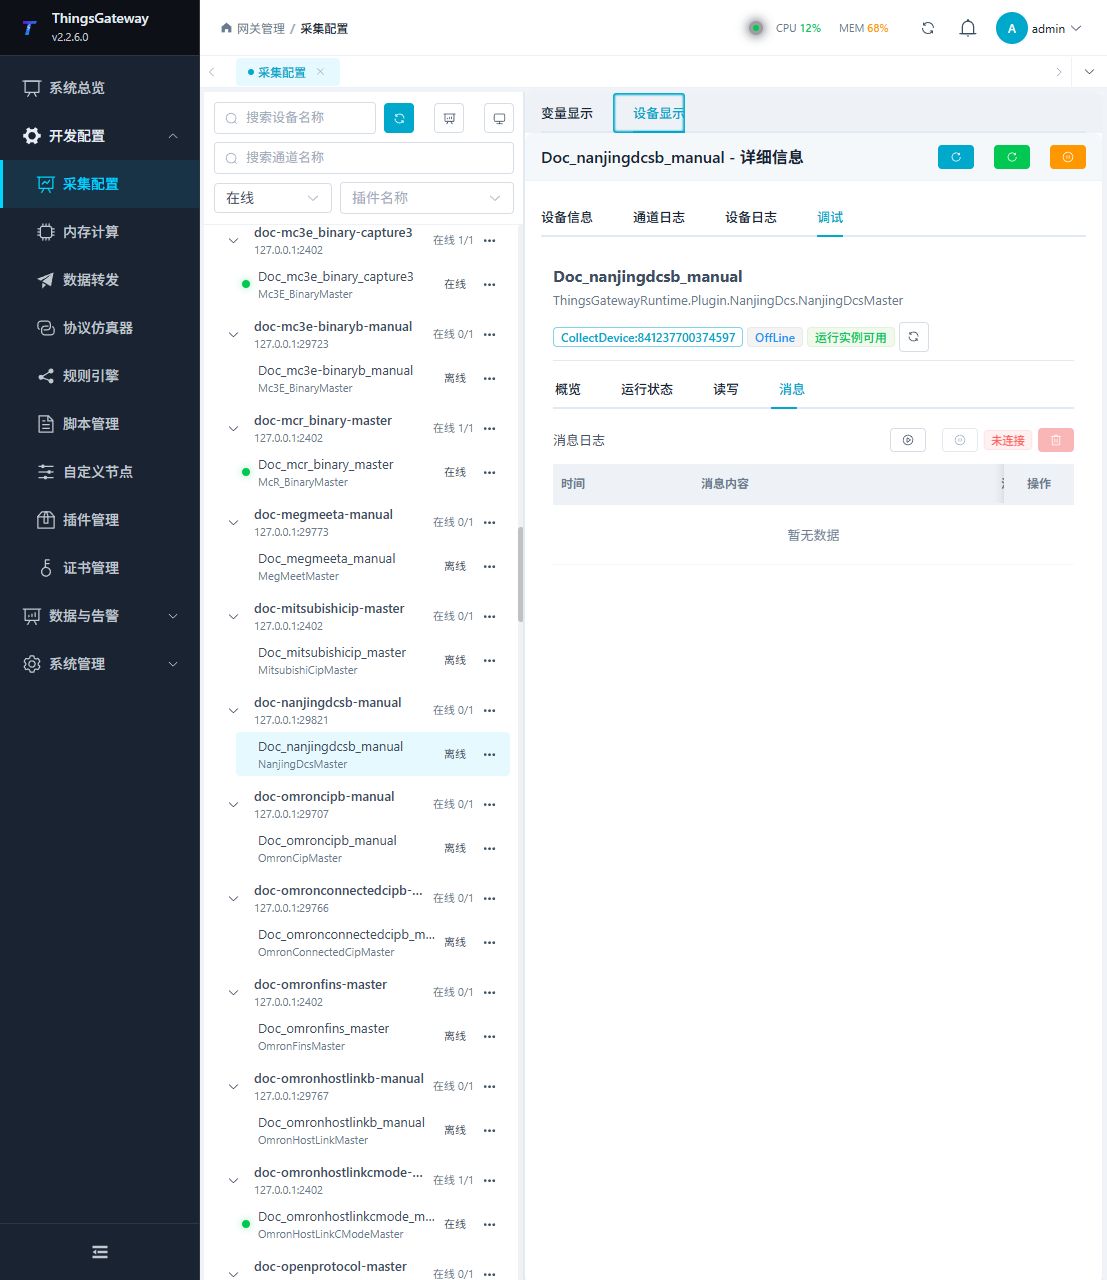
| Messages | Shows the connection probe, status frame, requests, and responses. |
Read/Write
Enter the address, data type, and array length. Read a known point first and write only after site approval.
Messages
Start message capture to inspect the connection probe, leading status frame, request, and Modbus response.
Verify the configuration
- After connecting, confirm the status frame under Messages.
- Read one known register and verify the station, value, data type, and byte order.
- Write only an approved test point and read it back as required by the site.
Troubleshooting
| Symptom | Check |
|---|---|
| Device remains offline after reconnect | DCS station, holding-register-zero probe, and six-byte status frame. |
| Address read fails | Address area, station, function code, and DCS point list. |
| Value is incorrect | Data type, default CDAB byte order, and register overlap. |
| Standard Modbus response is received but connection fails | Verify that the device is a Nanjing DCS requiring the status frame; otherwise use the standard Modbus plugin. |
Related links
- Collection Configuration: Common channels, devices, variables, and data format.
- Plugin Manual Index: Other collection and data-forwarding plugins.